Research
What I Do
I aim to build intelligent navigation systems that enable robots to operate autonomously in complex, unstructured environments.
Research Themes
Foundation Models for Embodied AI
Developing LLM/VLM-based systems that connect perception, reasoning, and action, enabling robots to interpret complex environments and adapt their decisions to changing conditions.World Models for Embodied Intelligence
Learning action-conditioned models of physical environments and robot behavior to predict future states, anticipate interaction outcomes, and support decision-making under uncertainty.Deep Reinforcement Learning for Robot Control
Developing adaptive control policies for mobile and legged robots, with a focus on sample-efficient learning, hierarchical control, and transfer from simulation to the real world.Machine Learning-Augmented Motion Planning
Combining learned representations, prior experience, and classical planning to generate efficient, dynamically feasible motions in cluttered and challenging environments.
Future Directions
My future research will connect foundation models, predictive world models, and reinforcement learning to enable robots to adapt to unfamiliar environments, reason about the consequences of their actions, and operate reliably under physical constraints.
Hardware Platforms
I work with diverse robot platforms to validate algorithms in both simulation and real-world environments.
| Robot | Image | Type | Use Case |
|---|---|---|---|
| Unitree Go1 | 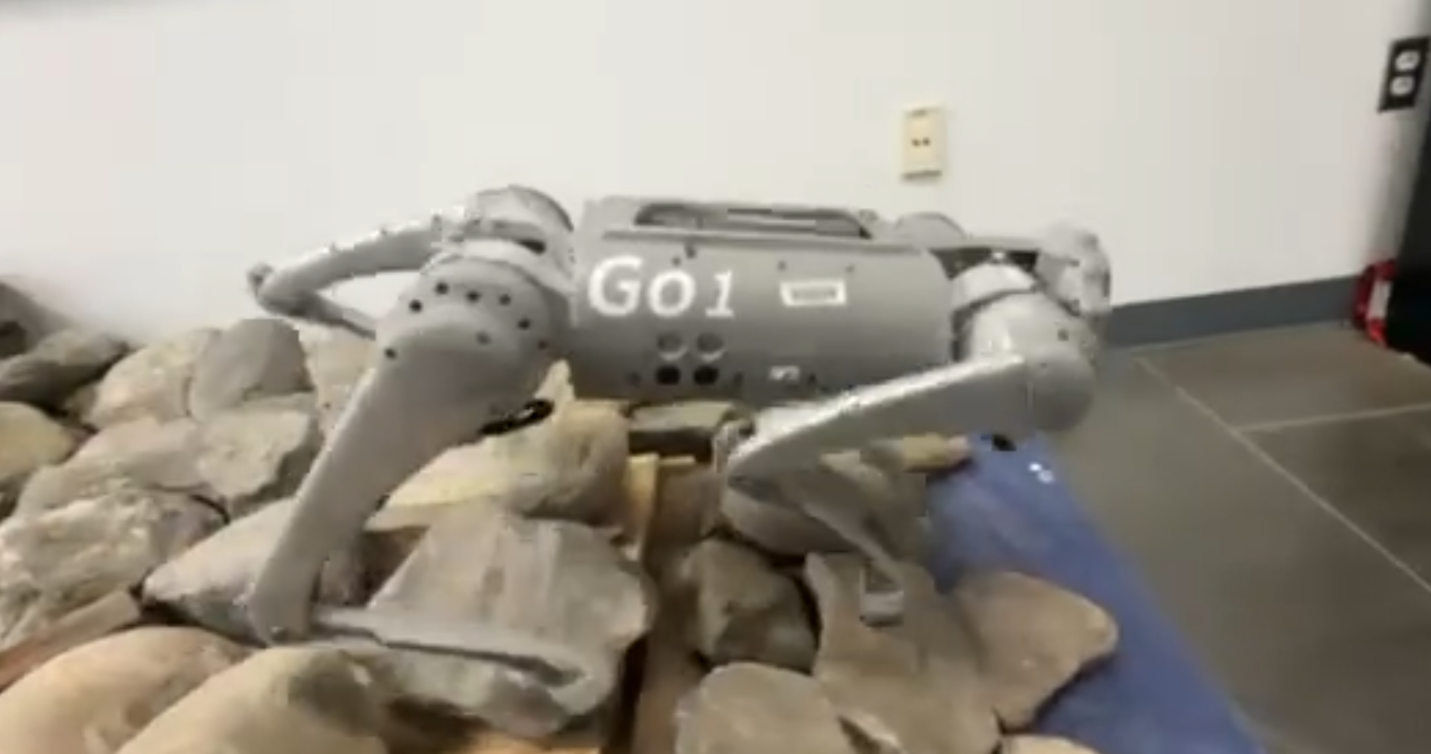 | Quadruped | Visual–LiDAR fusion, RL locomotion |
| Unitree Go2 | 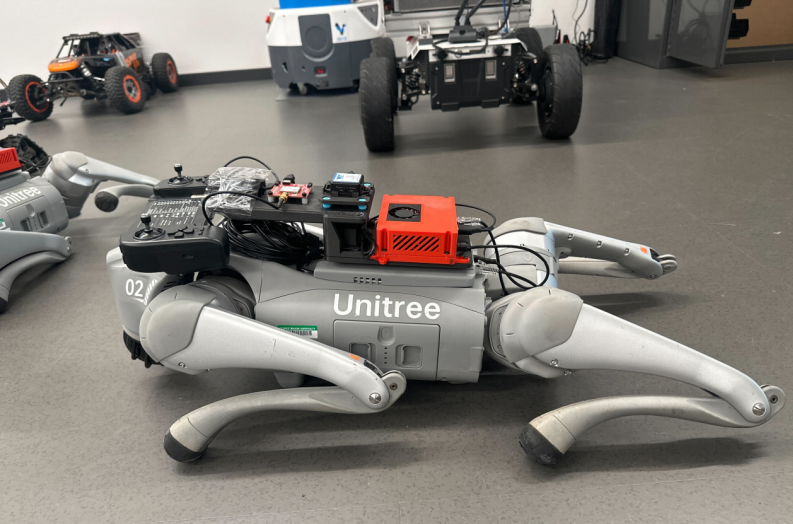 | Quadruped | VLM navigation, cross-modal perception |
| Unitree G1 | 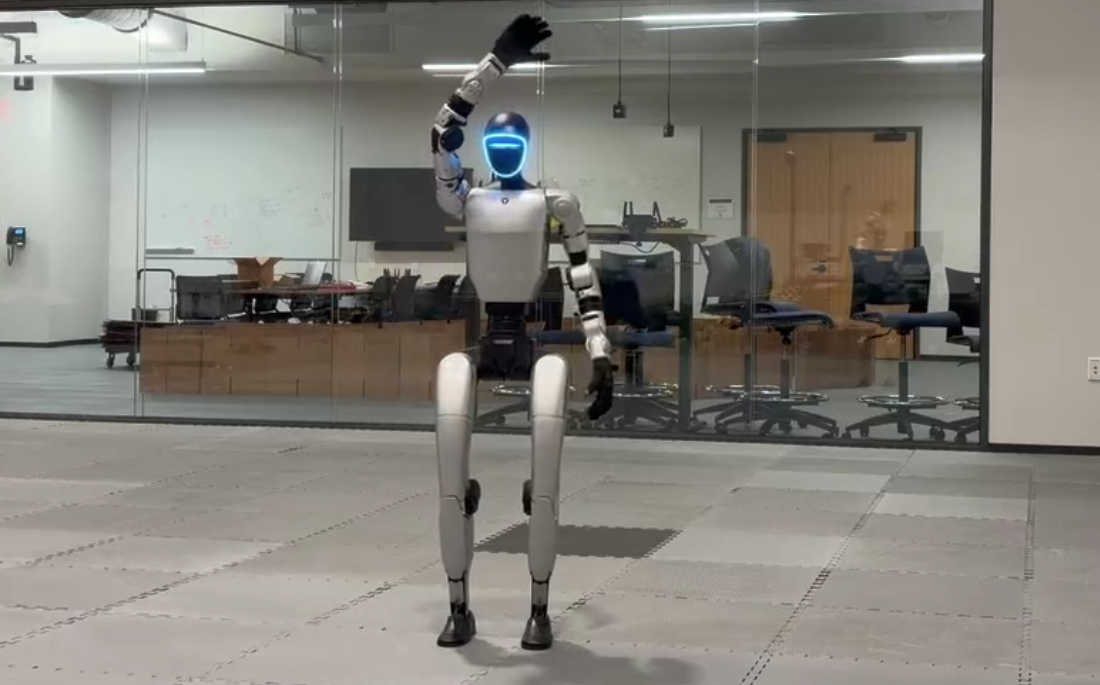 | Humanoid | LLM-guided policy learning |
| Clearpath Jackal | 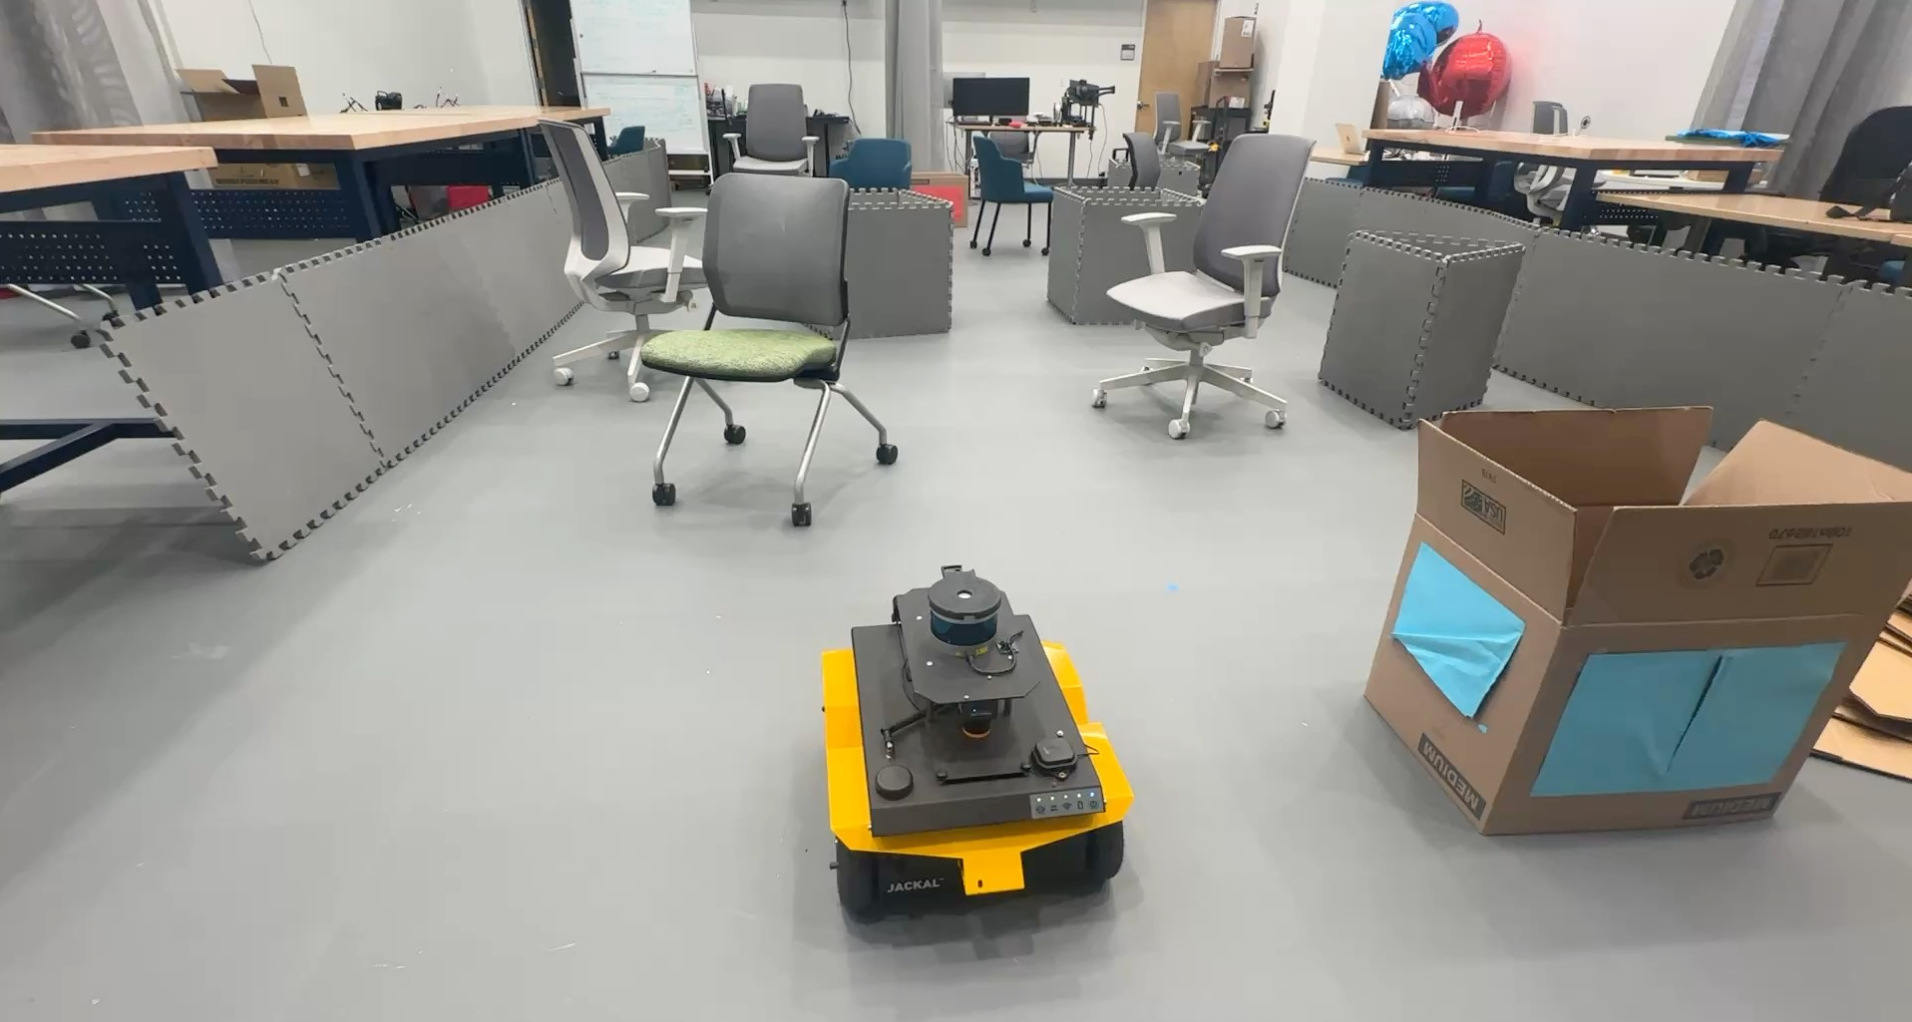 | Wheeled UGV | Real-world navigation testing |
| Clearpath Husky | 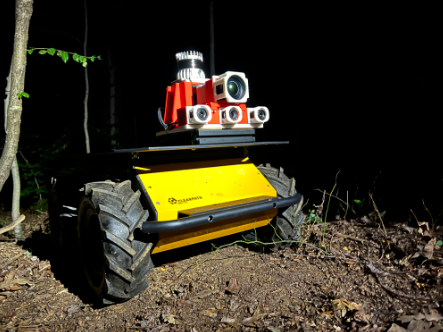 | Wheeled UGV | Outdoor mapping, multi-sensor fusion |
Simulation Environments
I design and use multiple simulation platforms for both classical planning and learning-based navigation.
| Environment | Image | Description |
|---|---|---|
| Gazebo | 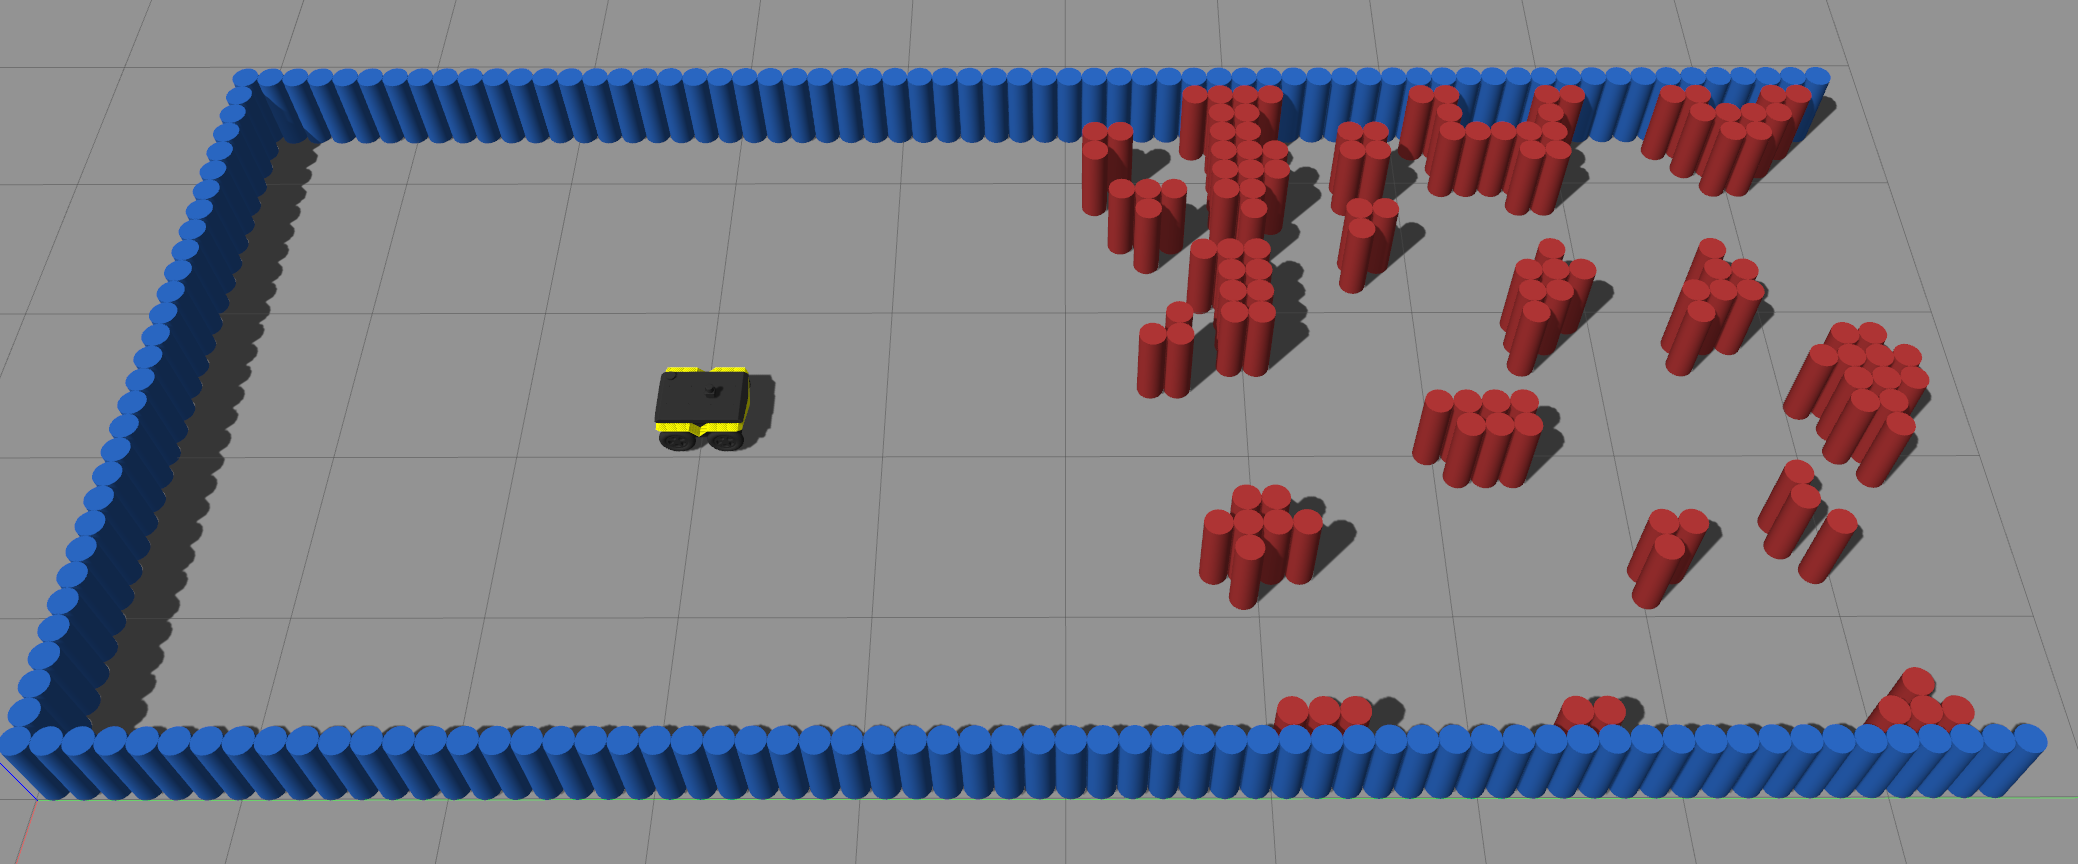 | Classic ROS-based simulator for wheeled robots, supporting costmaps, sensor fusion, and realistic physics. |
| Isaac Gym | 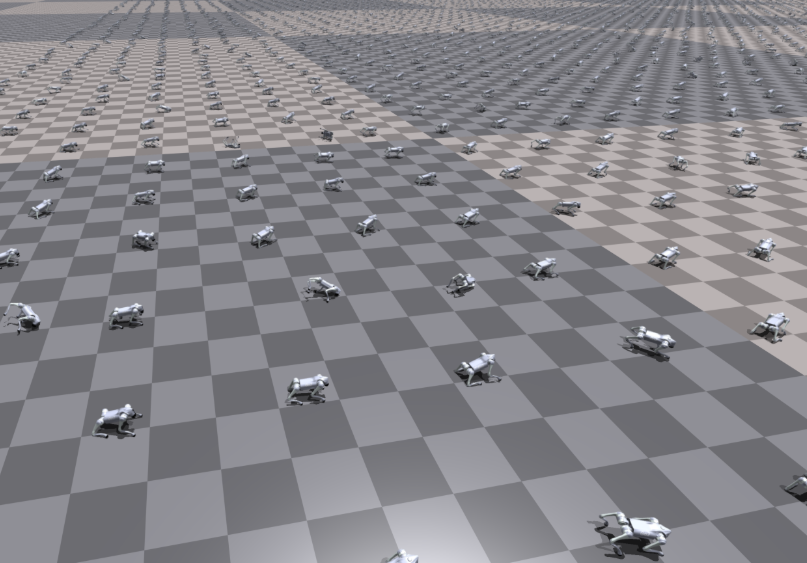 | GPU-accelerated simulation for large-scale reinforcement learning and policy optimization. |
| Isaac Sim | 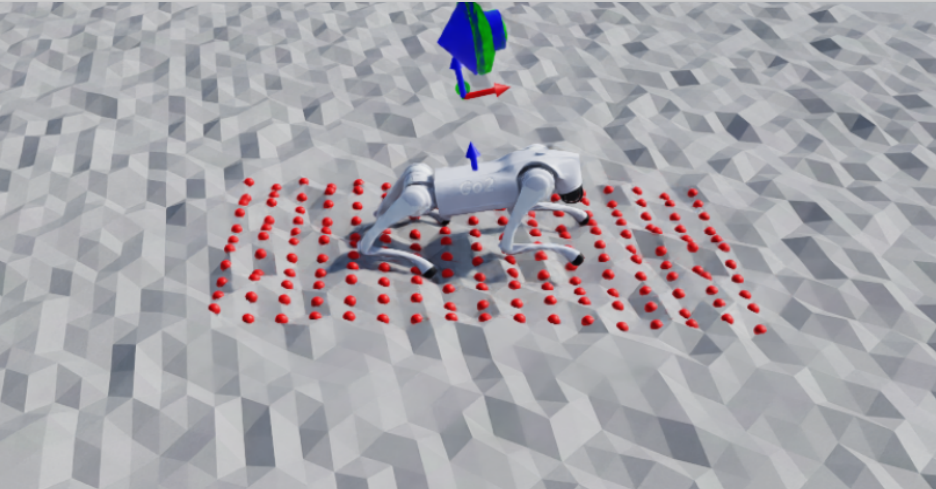 | High-fidelity NVIDIA Omniverse simulator for perception, dynamics, and multi-robot coordination. |
| Newton | Legged locomotion simulation and policy evaluation across diverse terrains. | |
| MuJoCo | Closed-loop simulation of robot dynamics, locomotion control, and autonomous navigation. | |
| mjlab | Unitree Go2 locomotion simulation using mjlab and MuJoCo Warp. | |
| Custom Terrains | 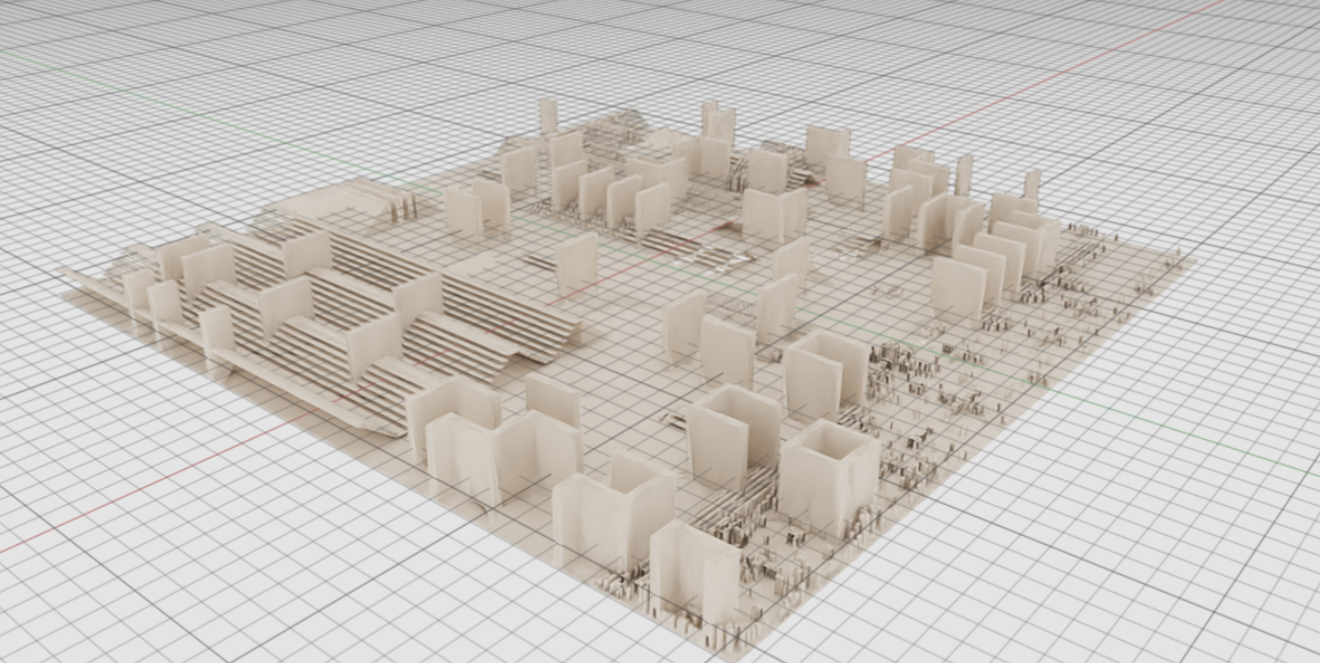 | Procedurally generated terrains for testing locomotion, stability, and adaptive control. |
| Self-design Simulation | self-design simulation using C++ for motion planning or multi-goal motion planning. |