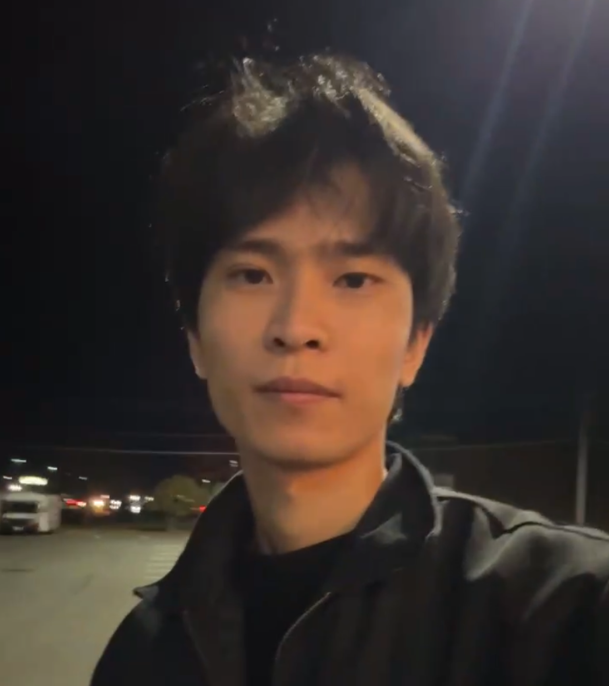
Short Bio
Yuanjie Lu is a PhD candidate in Computer Science at George Mason University, advised by Prof. Xuesu Xiao in the RobotiXX Lab. He is also affiliated with the Center for Human-AI Innovation in Society. His research focuses on embodied AI and robot learning, with an emphasis on foundation models, world models, and deep reinforcement learning for autonomous navigation and control. He develops methods that integrate LLM/VLM-based reasoning, world models, and deep reinforcement learning for robot planning and control in complex environments. His research includes applications to wheeled and legged navigation, as well as humanoid locomotion. He is seeking industry positions as a Research Scientist or Machine Learning Engineer in embodied AI, robot learning, and foundation models.
Research Interests
- Foundation Models for Embodied AI: LLM/VLM-based reasoning, planning, and adaptation for autonomous robots
- World Models for Embodied Intelligence: Learning predictive representations of the physical world for action-conditioned prediction, planning, and control
- Deep Reinforcement Learning for Robot Control: Adaptive and hierarchical control, policy learning, and sim-to-real transfer
- Machine Learning-Augmented Motion Planning: Integrating learned models, planning memory, and classical planners for efficient, executable motion
Collaborations
His research journey has progressed from machine learning and deep learning for autonomous systems, through motion planning algorithms in robotics, to real-world robot navigation and foundation model-driven autonomy.
| Collaborator | Topic |
|---|---|
| Dr. Dongqi Han and Dr. Dongsheng Li Microsoft Research Asia (MSRA) | Dynamics-aware navigation for quadruped robots |
| Prof. Chengzhi Mao Rutgers University | Reliable multimodal reasoning and trustworthy foundation models |
| Prof. Xiaomin Lin University of South Florida | LLM/VLM-driven robot navigation |
| Zhenyu Yang Chief Researcher, OPPO Xiaobu Assistant | Natural language processing, large language models, and conversational AI |
| Prof. Tinoosh Mohsenin Johns Hopkins University | Quadruped navigation |
| Prof. Nick Hawes Oxford University | Robot dynamics and adaptive control |
| Prof. Erion Plaku U.S. National Science Foundation (NSF), CISE | Motion planning that integrates learning with classical planners |
| Virginia Transportation Research Council | Graph neural networks for traffic flow forecasting under work zones and lane closures |
| Prof. Amarda Shehu and Prof. David Lattanzi George Mason University | Data-driven anomaly forecasting for autonomous systems |
Experiences
Research Intern
May–August 2026
Research Engineer Intern
May–August 2025
Digital Innovation Summer Experiential Fellow
May–August 2024
Remote Researcher
Nov 2024 - May 2025
Summer Research Assistant · VTRC-sponsored project
May–August 2020
Recent Publications & Projects
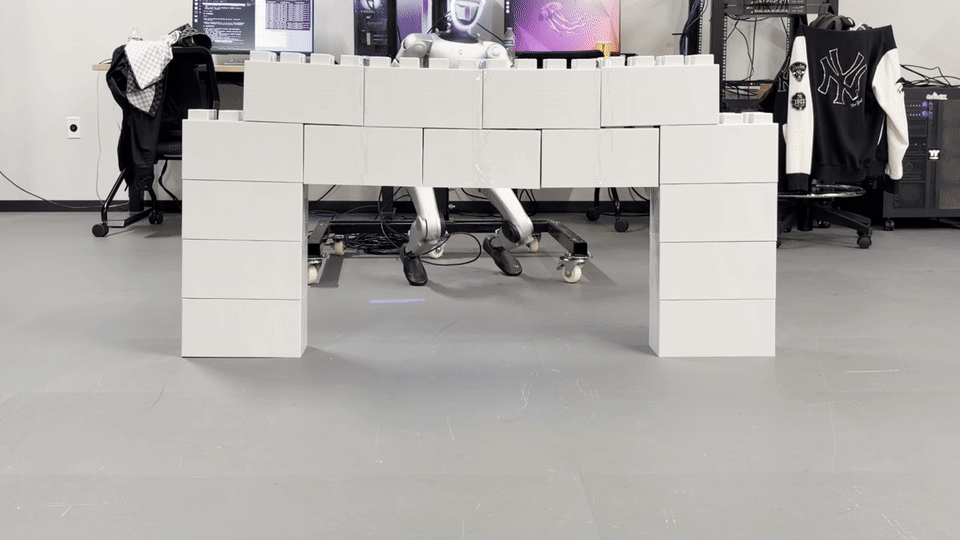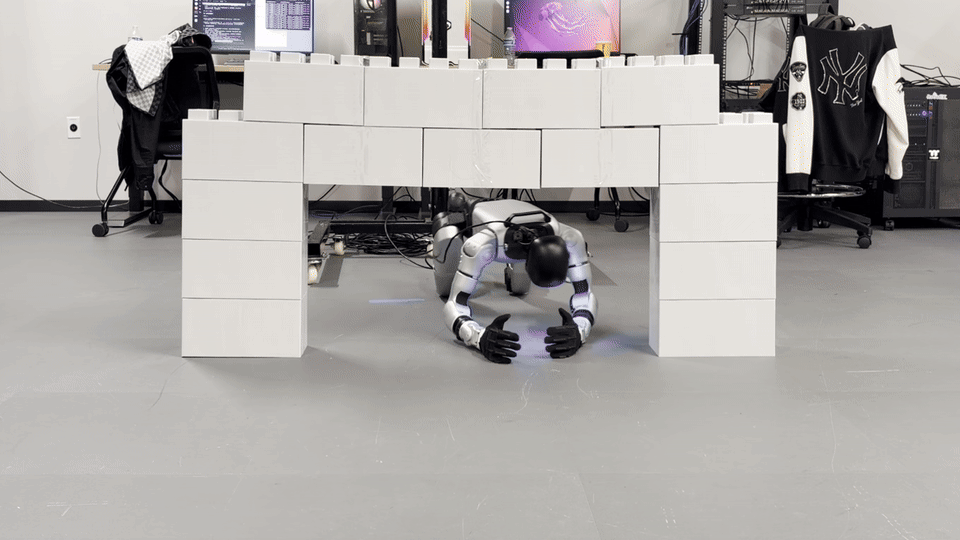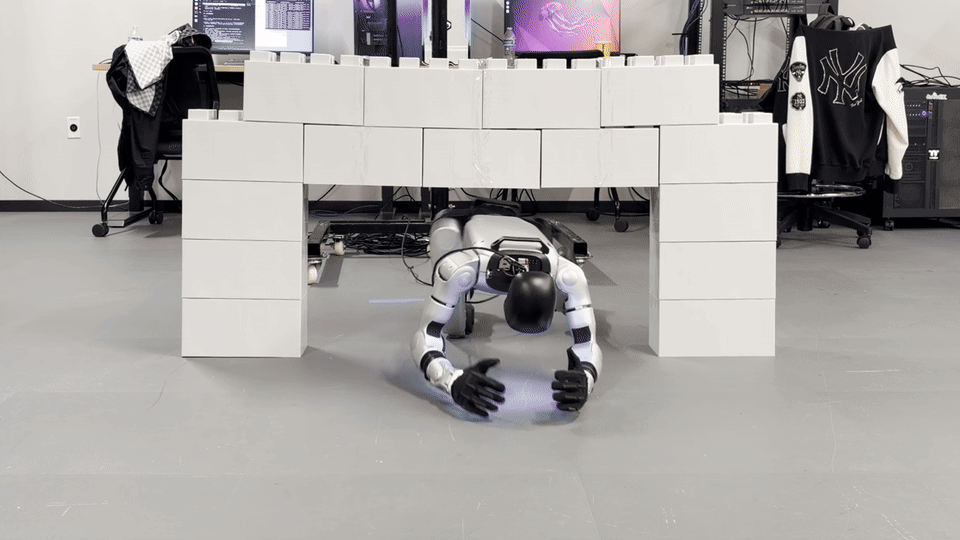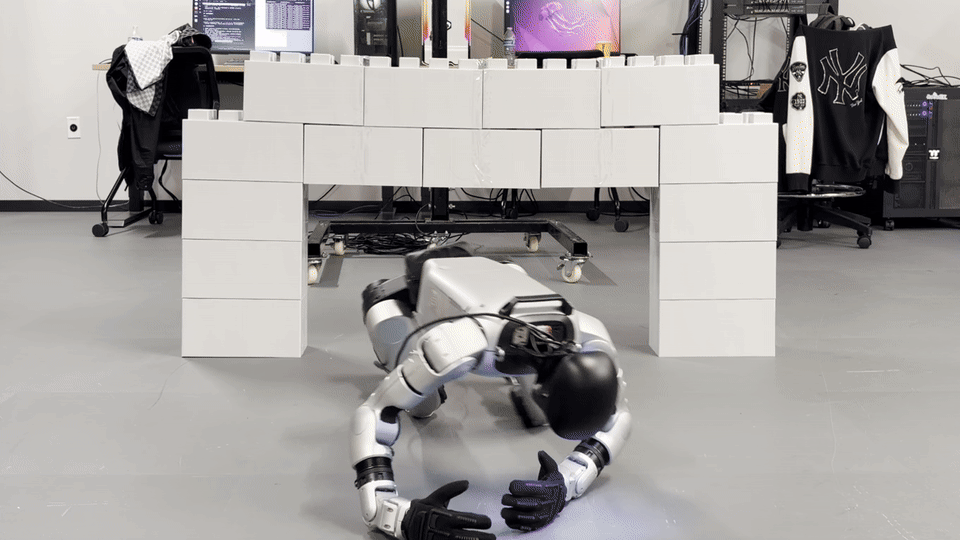
Learning Scene-Aware Humanoid Locomotion through 3D Clutter from Immersive Human Demonstrations (Submitted to ICRA 2027)
Learning scene-aware humanoid locomotion from immersive VR demonstrations, enabling a Unitree G1 to crawl through low passages and navigate narrow gaps.
Quadruped Navigation in Dense Obstacle Environments (Summer 2026 @ Microsoft Research Asia)
Quadruped navigation demonstrations in an indoor corridor with obstacles.
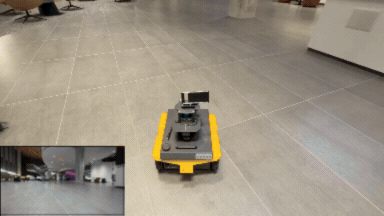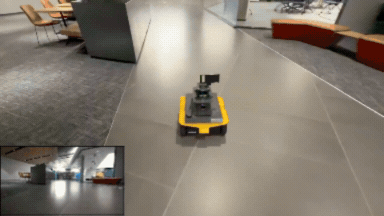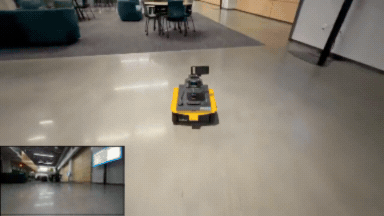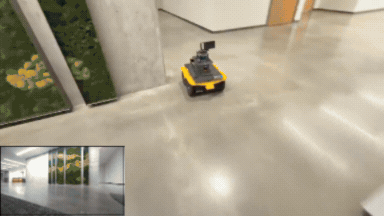
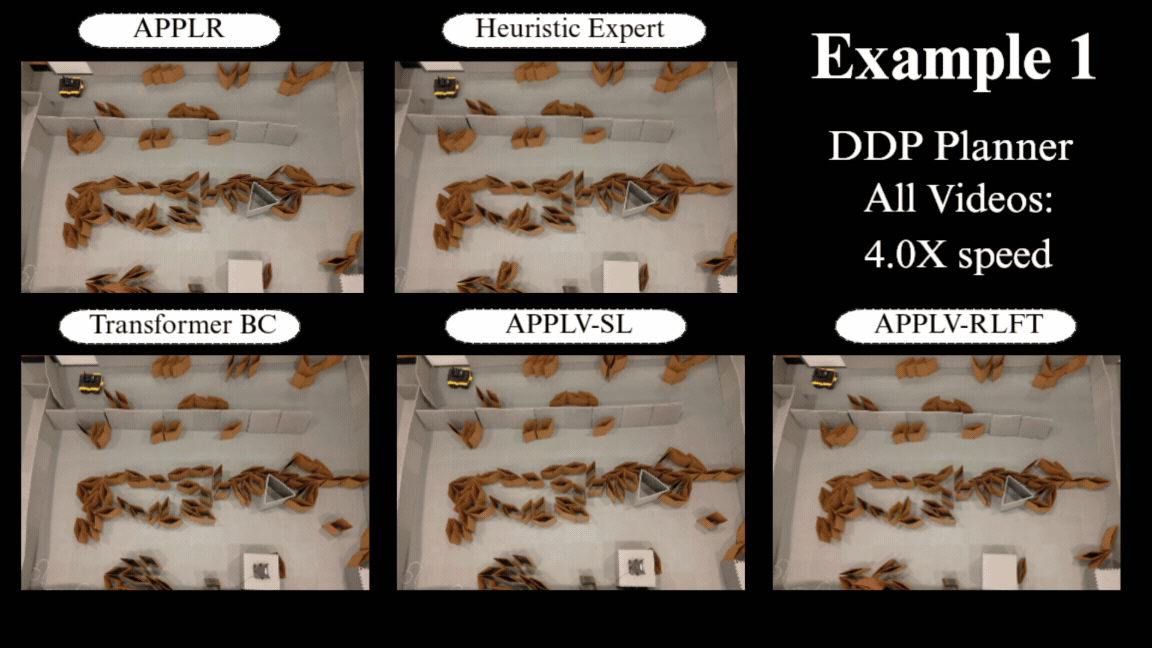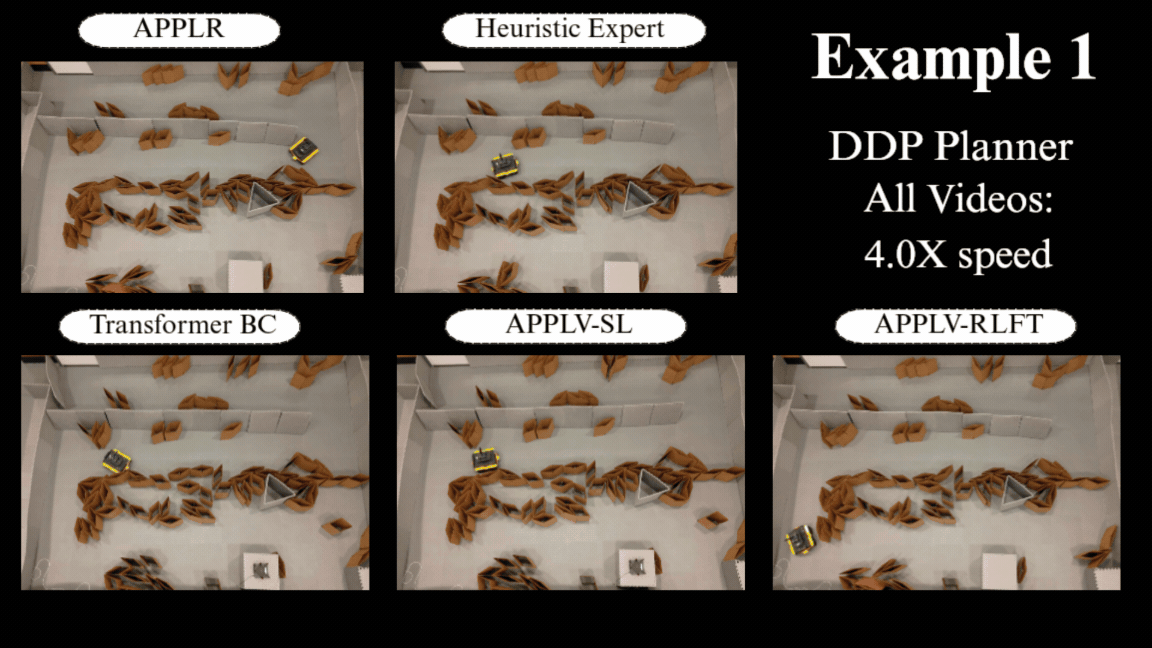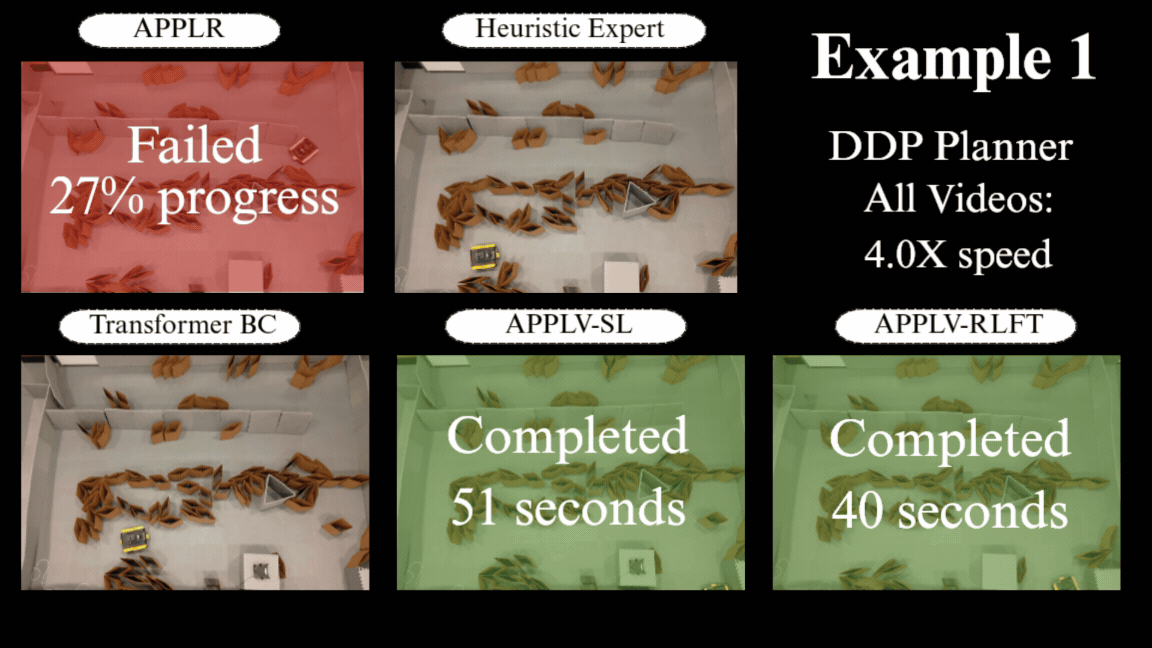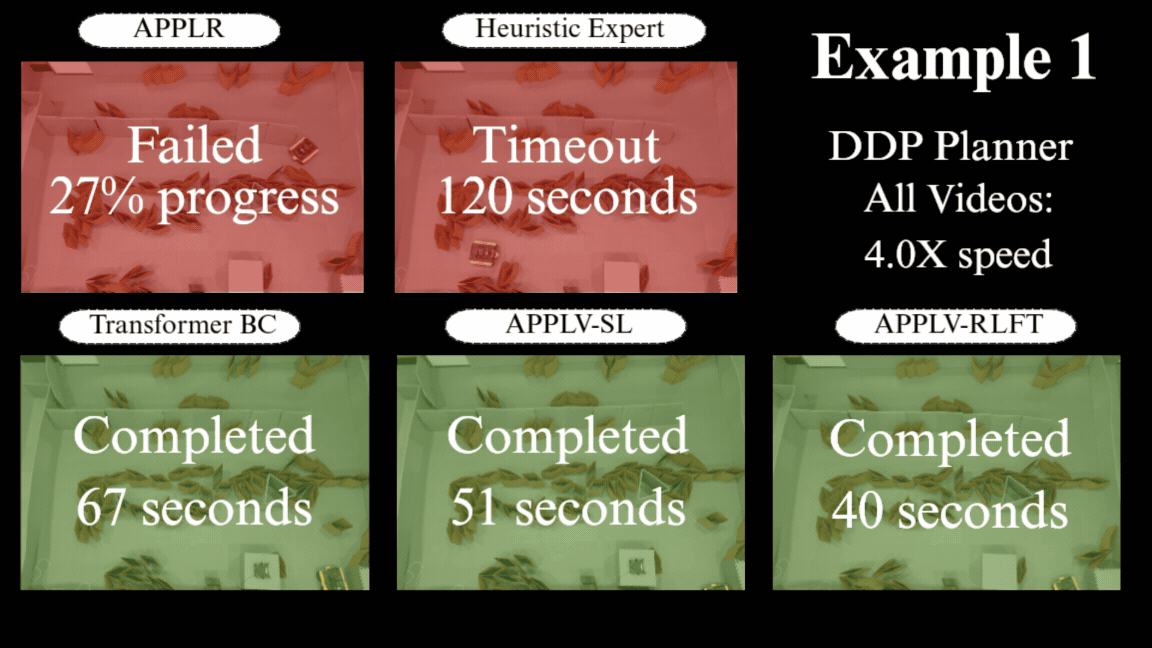
APPLV: Adaptive Planner Parameter Learning from Vision-Language-Action Model (IROS 2026)
This work studies how vision–language models (VLMs) can be leveraged to adaptively adjust classical motion planner parameters based on semantic and contextual understanding of the environment
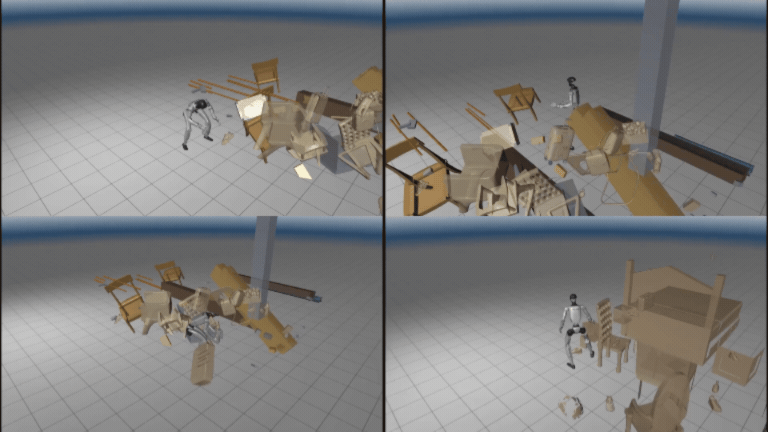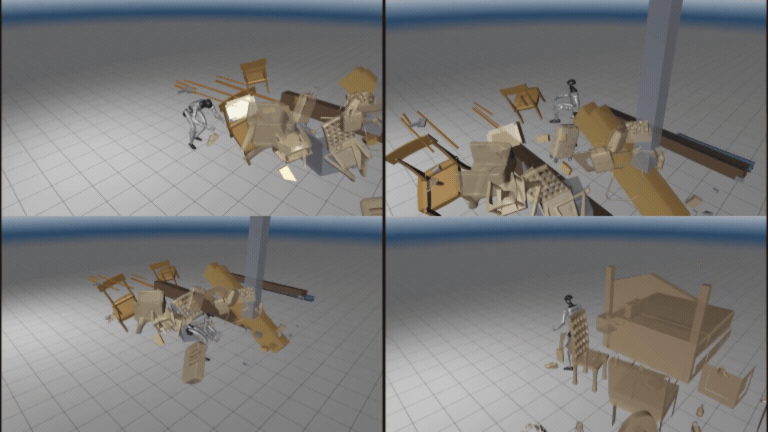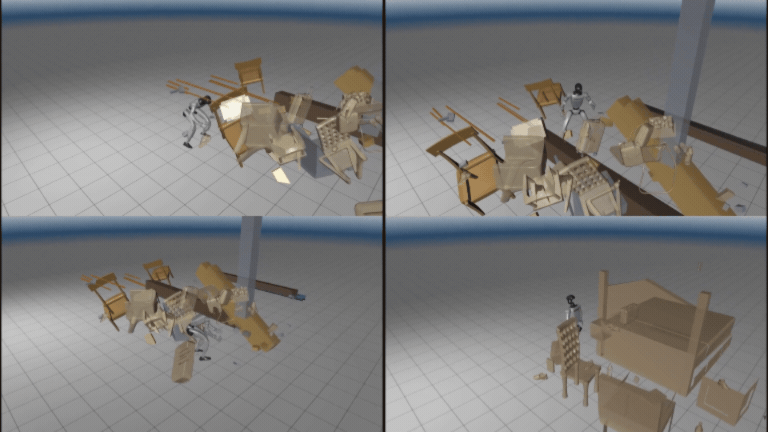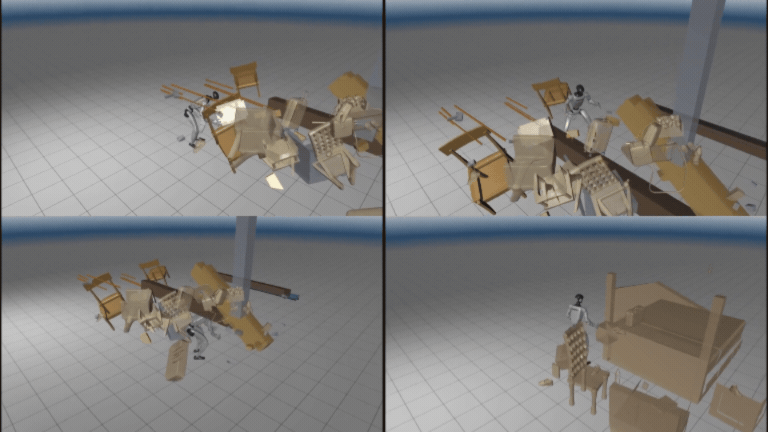
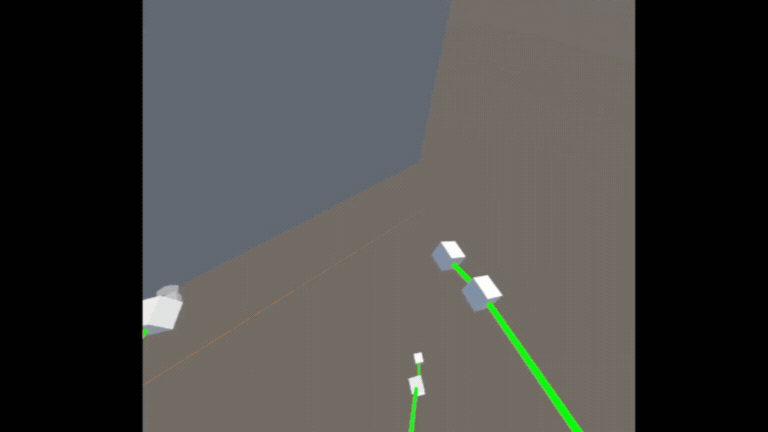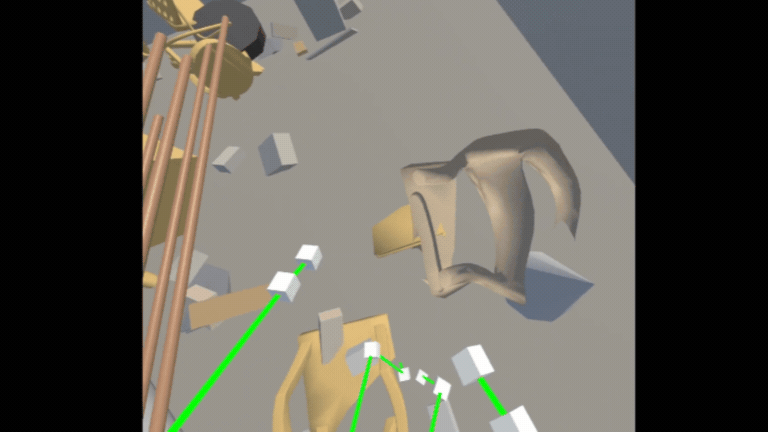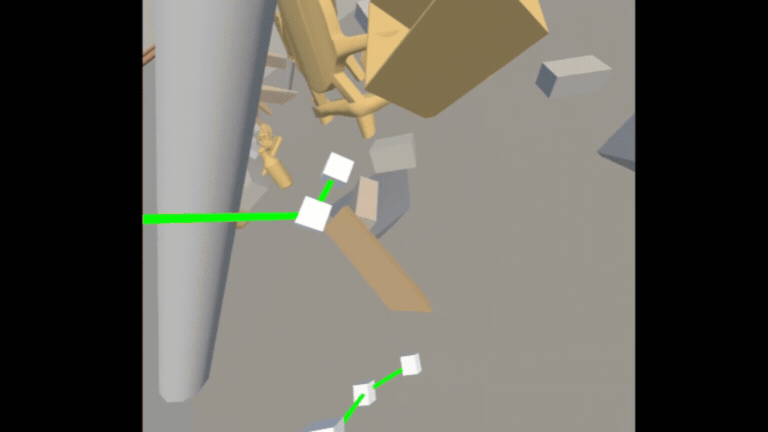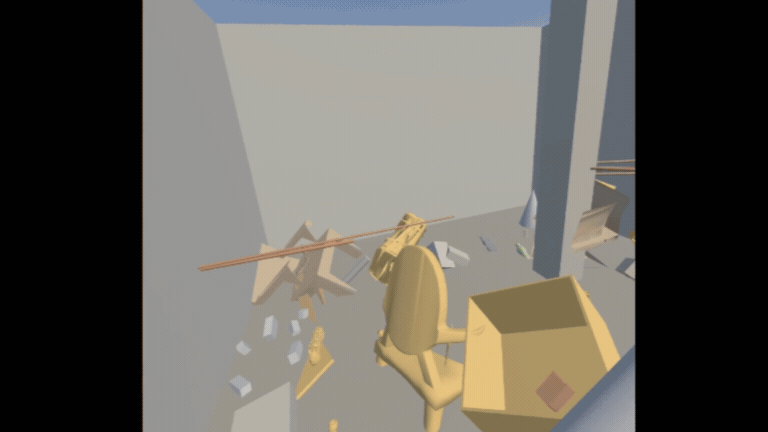
Moving Through Clutter: Scaling Data Collection and Benchmarking for 3D Scene-Aware Humanoid Locomotion via Virtual Reality
Generates scenes with controllable clutter levels and captures embodiment-consistent, whole-body human motion through immersive VR navigation
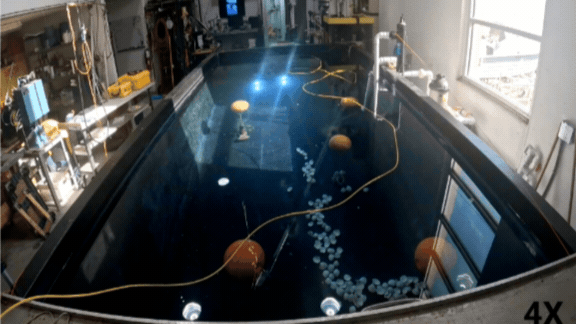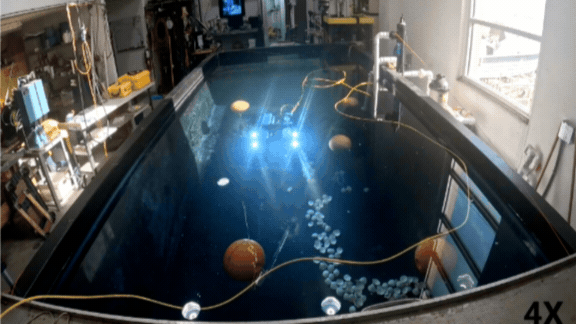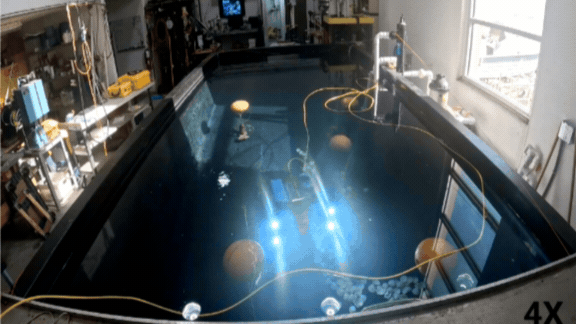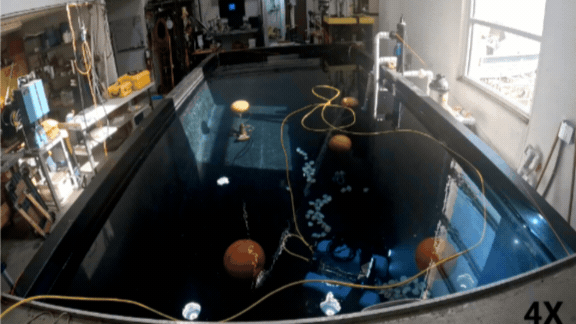
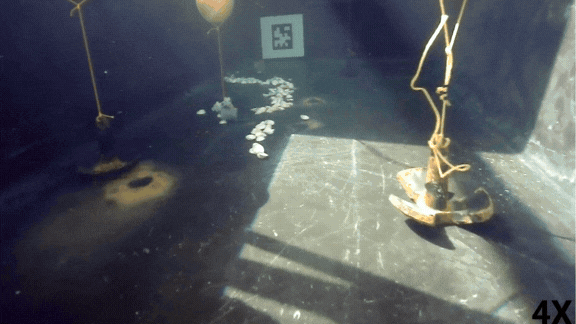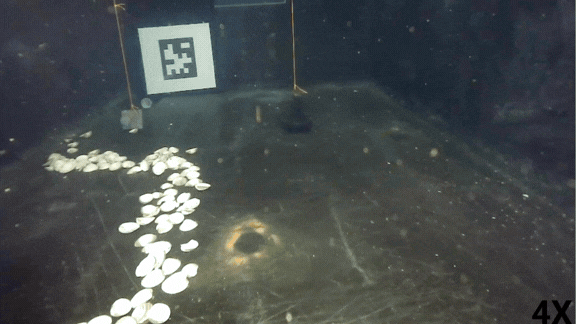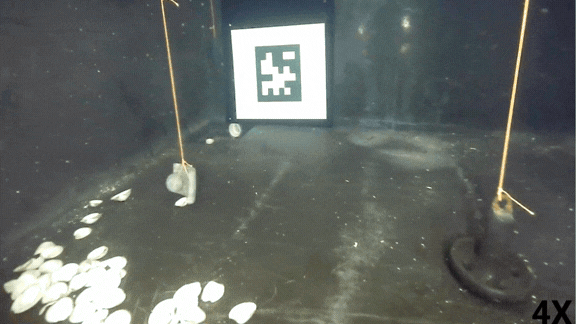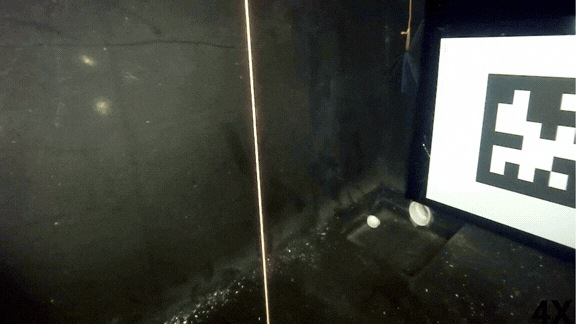
CORAL: Contextual Reasoning And Local Planning in A Hierarchical VLM Framework for Underwater Monitoring (IROS 2026)
a framework that decouples high-level semantic reasoning from low-level reactive control for underwater monitoring
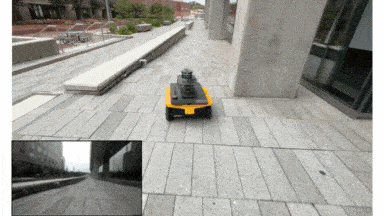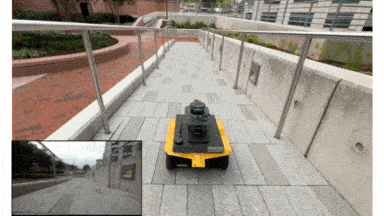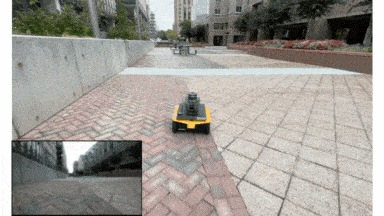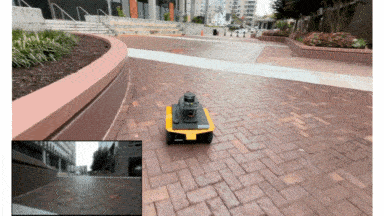
Adaptive Dynamics Planning (ADP) for Robot Navigation (ICRA 2026)
Combining Motion Planning with TD3-Based Reinforcement Learning for Real-Time Dynamics Adaptation in Mapless, Constrained Environments
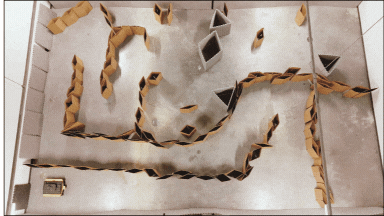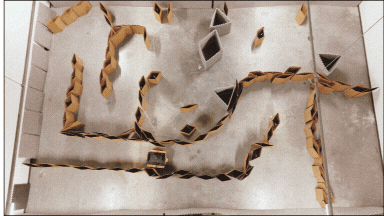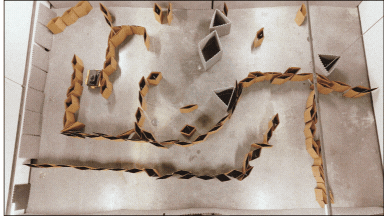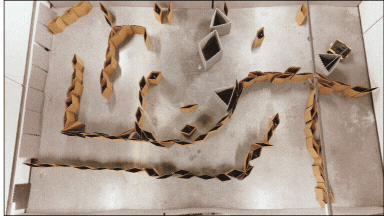
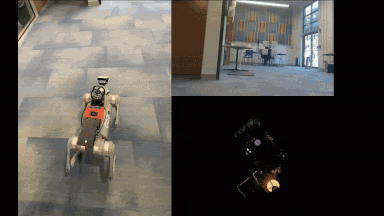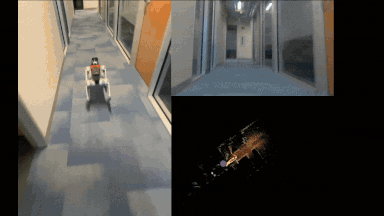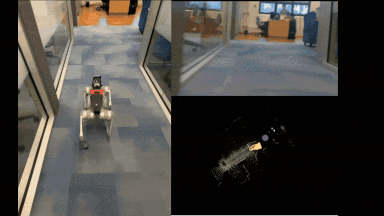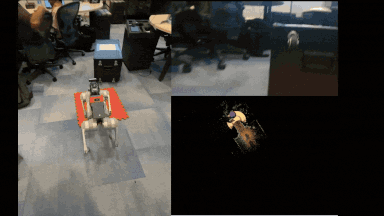
Autonomous Navigation for Legged Robots (Summer 2025 @ JHU)
Autonomous Navigation for Legged Robots in Complex Environments

News
- [Aug 2026] Our paper “CAVE-NAV: VLM-Based Autonomous 3D Navigation in Underwater Cave Environments” accepted to OCEANS 2026
- [Jun 2026] Our paper “APPLV: Adaptive Planner Parameter Learning from Vision-Language-Action Model” accepted to IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026.
- [Jun 2026] Our paper “CORAL: COntextual Reasoning And Local Planning in A Hierarchical VLM Framework for Underwater Monitoring” accepted to IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026.
- [May 2026] Started a three-month research internship at Microsoft Research Asia.
- [Feb 2026] Paper “Adaptive Dynamics Planning for Robot Navigation” accepted to IEEE ICRA 2026
- [Dec 2025] Built a custom dynamics-model-based navigation system with full ROS1/ROS2 compatibility, supporting modular design and planner adaptation.
- [Sep 2025] Fourth BARN Challenge at ICRA 2025 report “Autonomous Ground Navigation in Highly Constrained Spaces” (published in IEEE Robotics & Automation Magazine, 2026)
- [Jul 2025] Our work is supported by Google DeepMind, Clearpath Robotics, Raytheon Technologies, Tangenta, Mason Innovation Exchange (MIX), and Walmart
- [May 2025] Our paper “Decremental Dynamics Planning for Robot Navigation” accepted to IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025.
- [May 2025] Our paper “Reward Training Wheels: Adaptive Auxiliary Rewards for Robotics Reinforcement Learning” accepted to IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2025.
- [May 2025] Started Research Engineer position at Johns Hopkins University
- [Mar 2025] Our work is supported by National Science Foundation (NSF), Army Research Office (ARO) and Air Force Research Laboratory (AFRL)
- [Jan 2025] Paper “Multi-Goal Motion Memory” accepted to IEEE ICRA 2025