Publications
ICRA 2027 · Submitted
Learning Scene-Aware Humanoid Locomotion through 3D Clutter from Immersive Human Demonstrations
B. Wang, T. Xu, D. Kosukhin, Y.-H. Yeung, Y. Lu, X. Xiao Learning scene-aware humanoid locomotion from immersive VR demonstrations, enabling a Unitree G1 to crawl through low passages and navigate narrow gaps. | paper
B. Wang, T. Xu, D. Kosukhin, Y.-H. Yeung, Y. Lu, X. Xiao Learning scene-aware humanoid locomotion from immersive VR demonstrations, enabling a Unitree G1 to crawl through low passages and navigate narrow gaps. | paper
OCEANS 2026
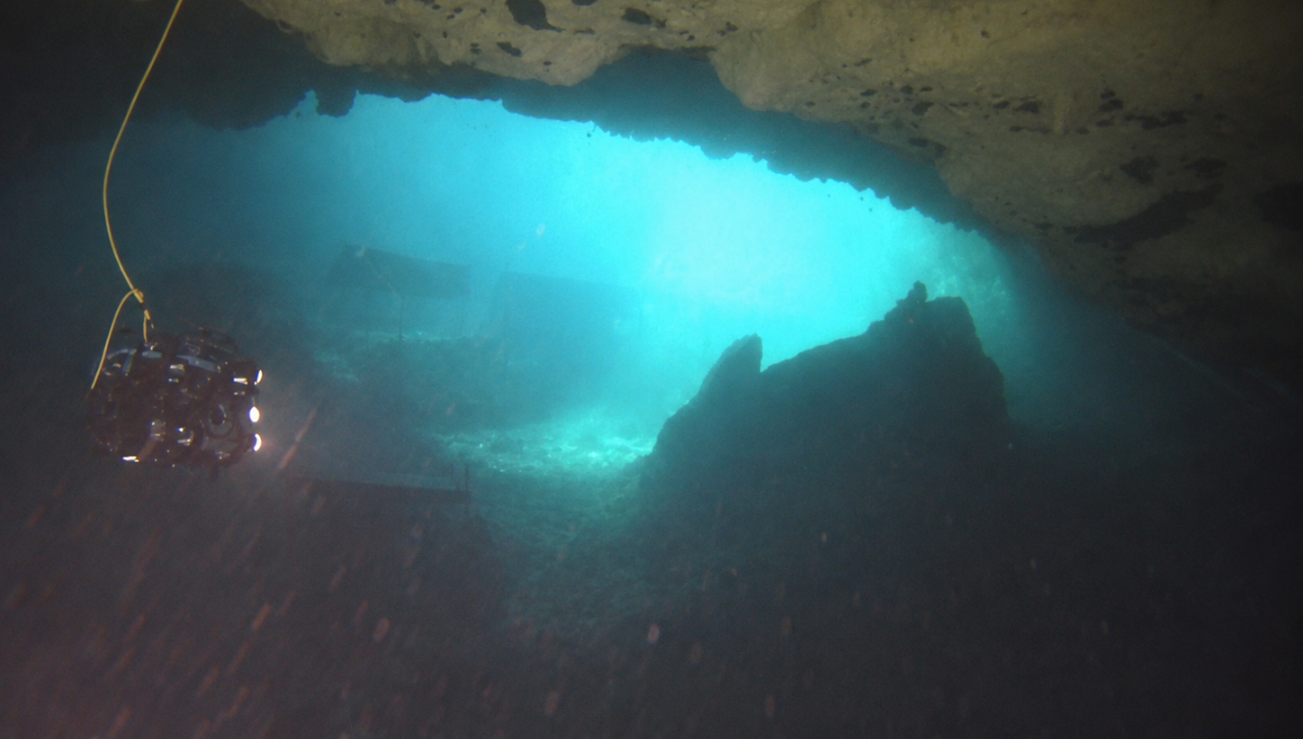
CAVE-NAV: VLM-Based Autonomous 3D Navigation in Underwater Cave Environments
Z. Wu, Y. Lu, Y. Zhang, M. Yu, X. Xiao, J. Shin, X. Lin — OCEANS 2026 Vision-language-guided 3D navigation through confined underwater caves using visual, depth, and sonar observations. | paper
Z. Wu, Y. Lu, Y. Zhang, M. Yu, X. Xiao, J. Shin, X. Lin — OCEANS 2026 Vision-language-guided 3D navigation through confined underwater caves using visual, depth, and sonar observations. | paper
IROS 2026
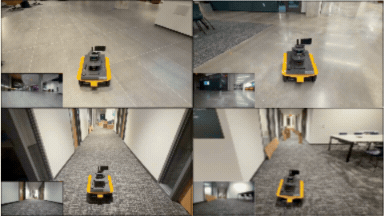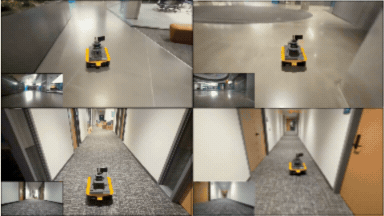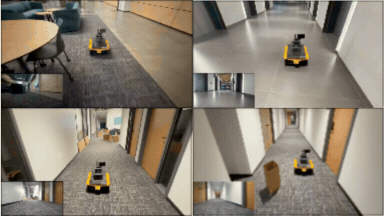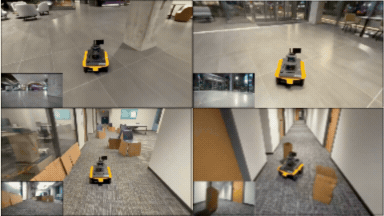
APPLV: Adaptive Planner Parameter Learning from Vision-Language-Action Model
Y. Lu, B. Wang, Z. Wu, Y. Li, X. Lin, C. Mao, X. Xiao — Accepted to IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026 Leverages a vision-language-action model to predict navigation planner parameters rather than actions directly. | paper
Y. Lu, B. Wang, Z. Wu, Y. Li, X. Lin, C. Mao, X. Xiao — Accepted to IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026 Leverages a vision-language-action model to predict navigation planner parameters rather than actions directly. | paper
IROS 2026
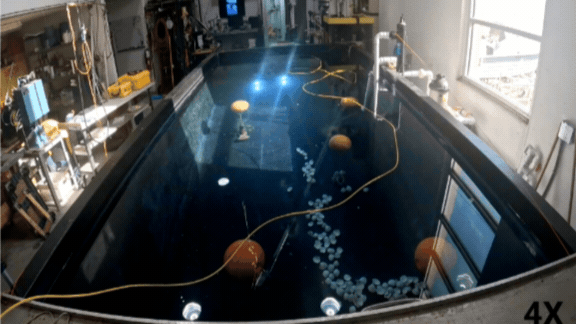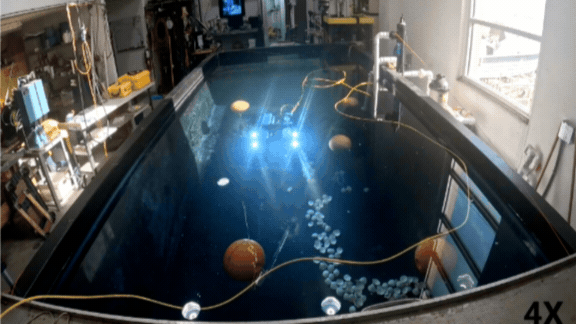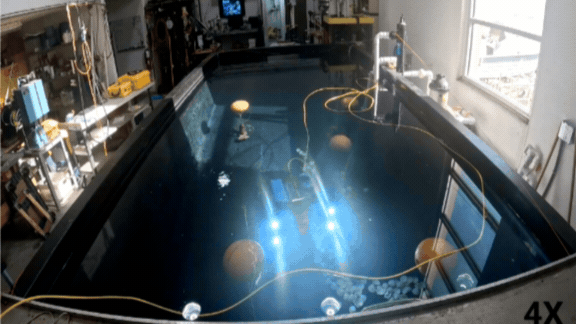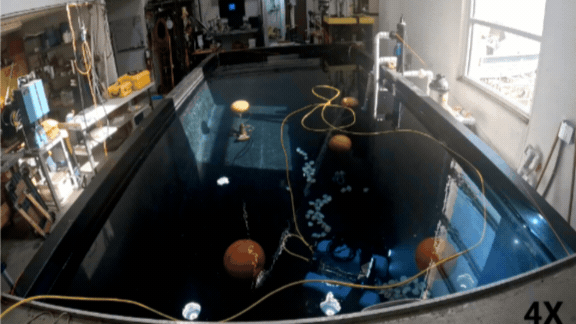
CORAL: COntextual Reasoning And Local Planning in A Hierarchical VLM Framework for Underwater Monitoring
Z. Wu, Y. Lu, X. Xiao, X. Lin — Accepted to IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026 A framework that decouples high-level semantic reasoning from low-level reactive control. | paper
Z. Wu, Y. Lu, X. Xiao, X. Lin — Accepted to IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026 A framework that decouples high-level semantic reasoning from low-level reactive control. | paper
ICRA 2026
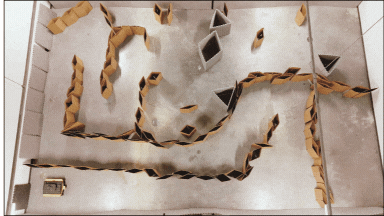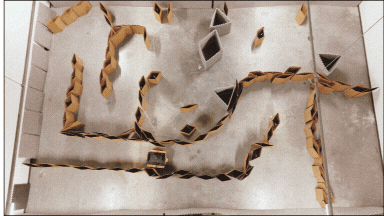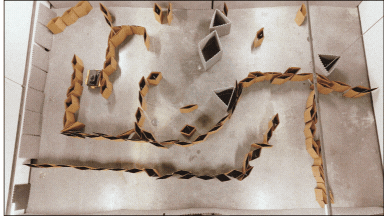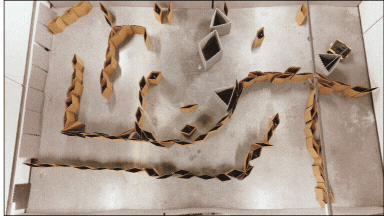
Adaptive Dynamics Planning for Robot Navigation
Y. Lu, M. Mao, T. Xu, L. Wang, X. Lin, X. Xiao — IEEE International Conference on Robotics and Automation (ICRA), 2026 Integrates adaptive dynamics modeling with learning-based local planners for efficient navigation in constrained environments. | paper
Y. Lu, M. Mao, T. Xu, L. Wang, X. Lin, X. Xiao — IEEE International Conference on Robotics and Automation (ICRA), 2026 Integrates adaptive dynamics modeling with learning-based local planners for efficient navigation in constrained environments. | paper
IROS 2025
IROS 2025
RSS 2025
RAM 2026
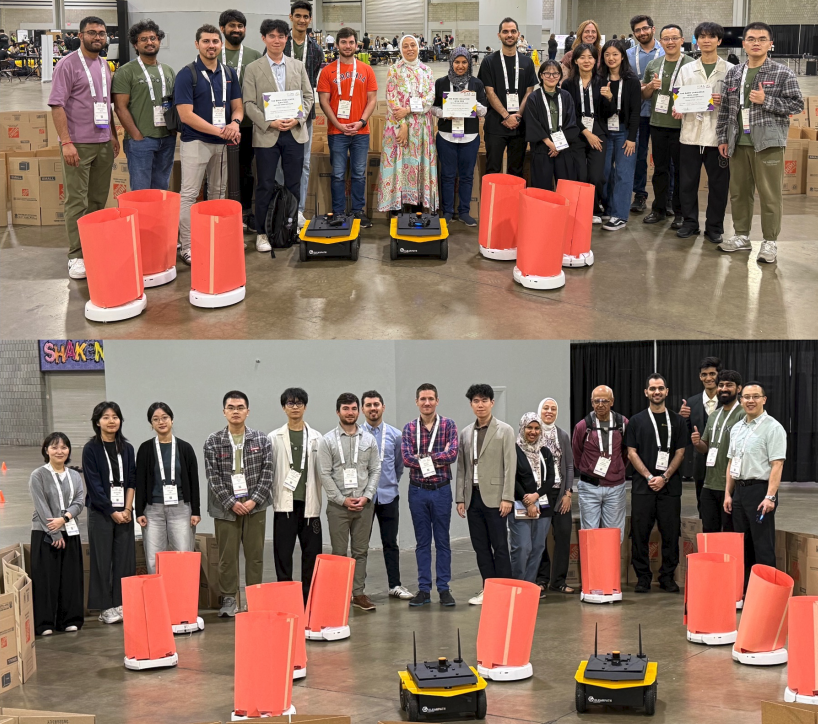
Autonomous Ground Navigation in Highly Constrained Spaces: Lessons Learned from the Fourth BARN Challenge at ICRA 2025
X. Xiao, Z. Xu, S. A. Ghani, A. Datar, D. Song, P. Stone, K. Yazdipaz, Y. Lu, … — IEEE Robotics & Automation Magazine, 33(1), 186–196, 2026 Report and analysis from large-scale constrained-space navigation benchmarking. | paper | website
X. Xiao, Z. Xu, S. A. Ghani, A. Datar, D. Song, P. Stone, K. Yazdipaz, Y. Lu, … — IEEE Robotics & Automation Magazine, 33(1), 186–196, 2026 Report and analysis from large-scale constrained-space navigation benchmarking. | paper | website
ICRA 2025
ICRA 2024
IROS 2023
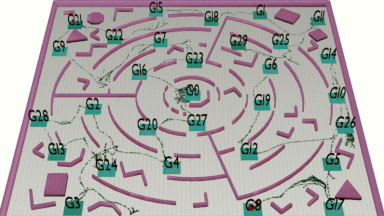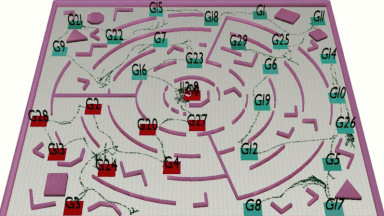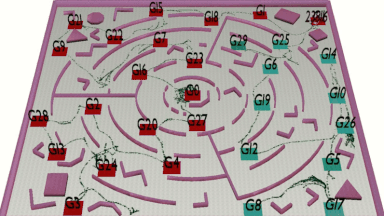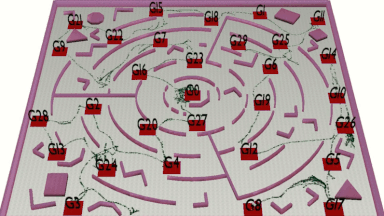
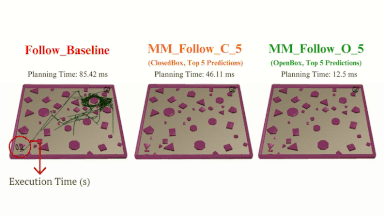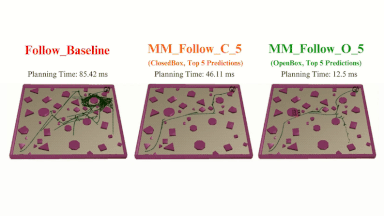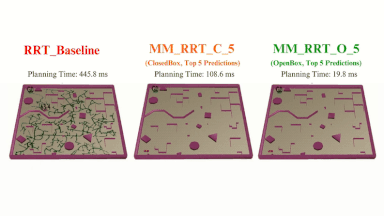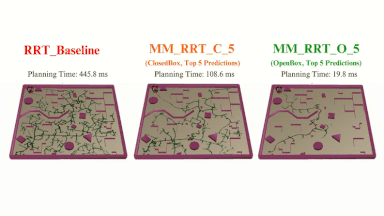
Leveraging Single-goal Predictions to Improve the Efficiency of Multi-goal Motion Planning with Dynamics
Y. Lu, E. Plaku — IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023 Single-goal predictors as priors to accelerate multi-goal planning with dynamics. | paper | video
Y. Lu, E. Plaku — IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023 Single-goal predictors as priors to accelerate multi-goal planning with dynamics. | paper | video
IROS 2022
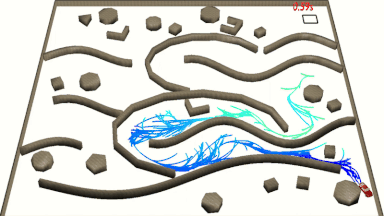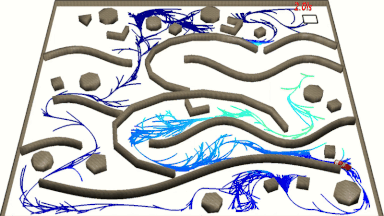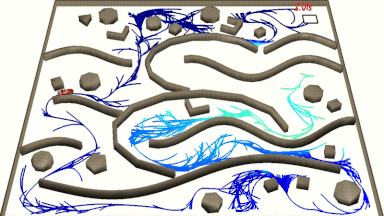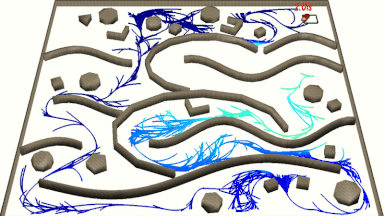
Improving the Efficiency of Sampling-based Motion Planners via Runtime Predictions for Motion-planning Problems with Dynamics
H. D. Bui, Y. Lu, E. Plaku — IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022 Runtime predictions informing sampling-based planning under dynamics. | paper | video
H. D. Bui, Y. Lu, E. Plaku — IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2022 Runtime predictions informing sampling-based planning under dynamics. | paper | video
Other Publications
IET 2026
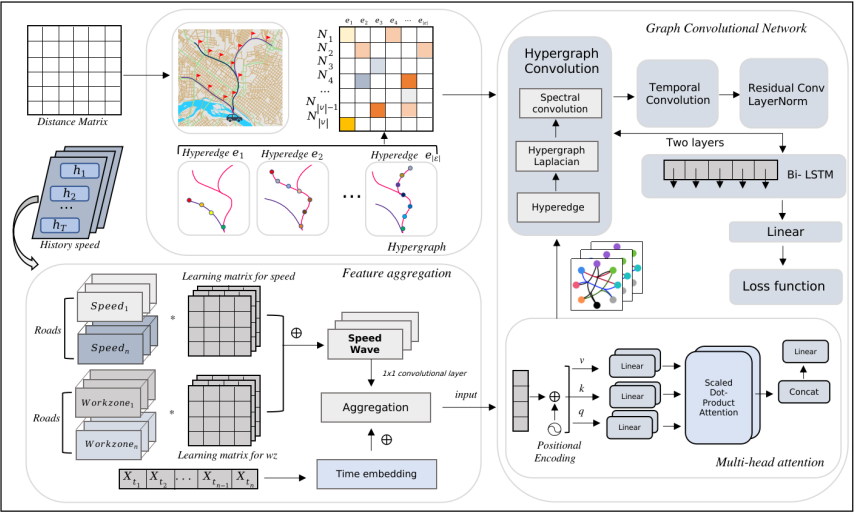
Accounting for Work Zone Disruptions in Traffic Flow Forecasting via Multi-Channel Attention-Based Spatio-Temporal Graph Convolutional Networks
Y. Lu, S. Zhu, A. Shehu, D. Lattanzi — IET Intelligent Transport Systems, 2026 paper
Y. Lu, S. Zhu, A. Shehu, D. Lattanzi — IET Intelligent Transport Systems, 2026 paper
BIBM 2021
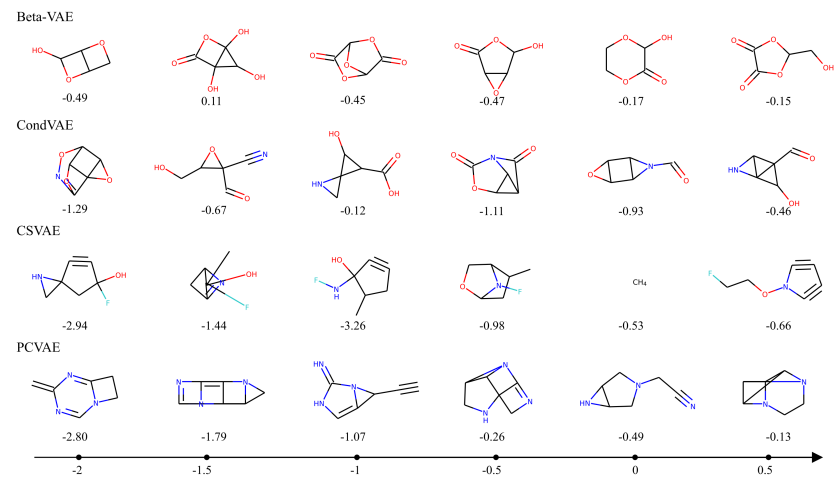
Deep Latent-variable Models for Controllable Molecule Generation
Y. Du, Y. Wang, F. Alam, Y. Lu, X. Guo, L. Zhao, A. Shehu — IEEE International Conference on Bioinformatics and Biomedicine (BIBM), 2021 Controllable molecule generation via latent-variable models. | paper
Y. Du, Y. Wang, F. Alam, Y. Lu, X. Guo, L. Zhao, A. Shehu — IEEE International Conference on Bioinformatics and Biomedicine (BIBM), 2021 Controllable molecule generation via latent-variable models. | paper